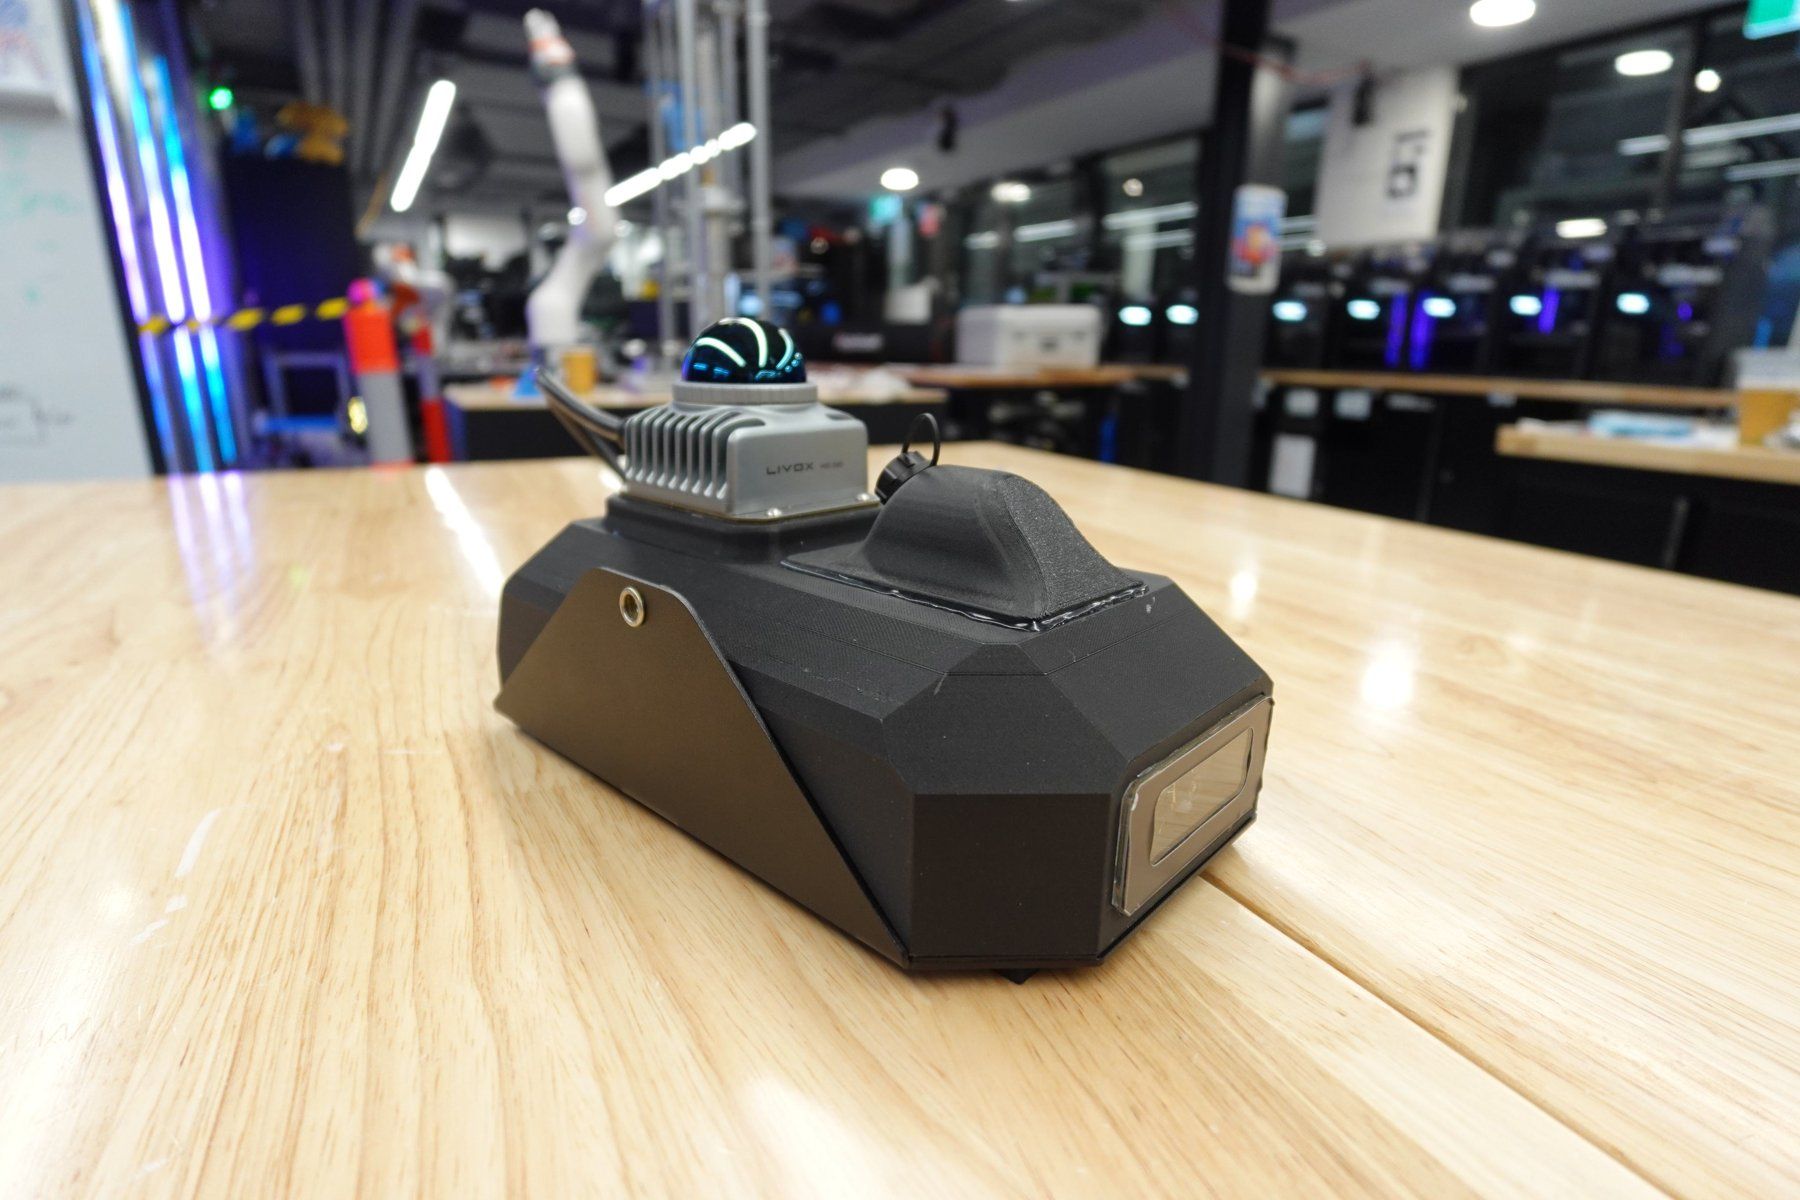
Bike Box
An on-bike data collection device that records how close passing cars get to cyclists.
- Program
- Research & FYP
- Status
- Deployed
- Monash Automation member
- David Phillips
- Project partners
- Prof. Ben Beck, Prof. Dana Kulic, Philip Pawlowski, Kal Backman, Philip Cho
Project background
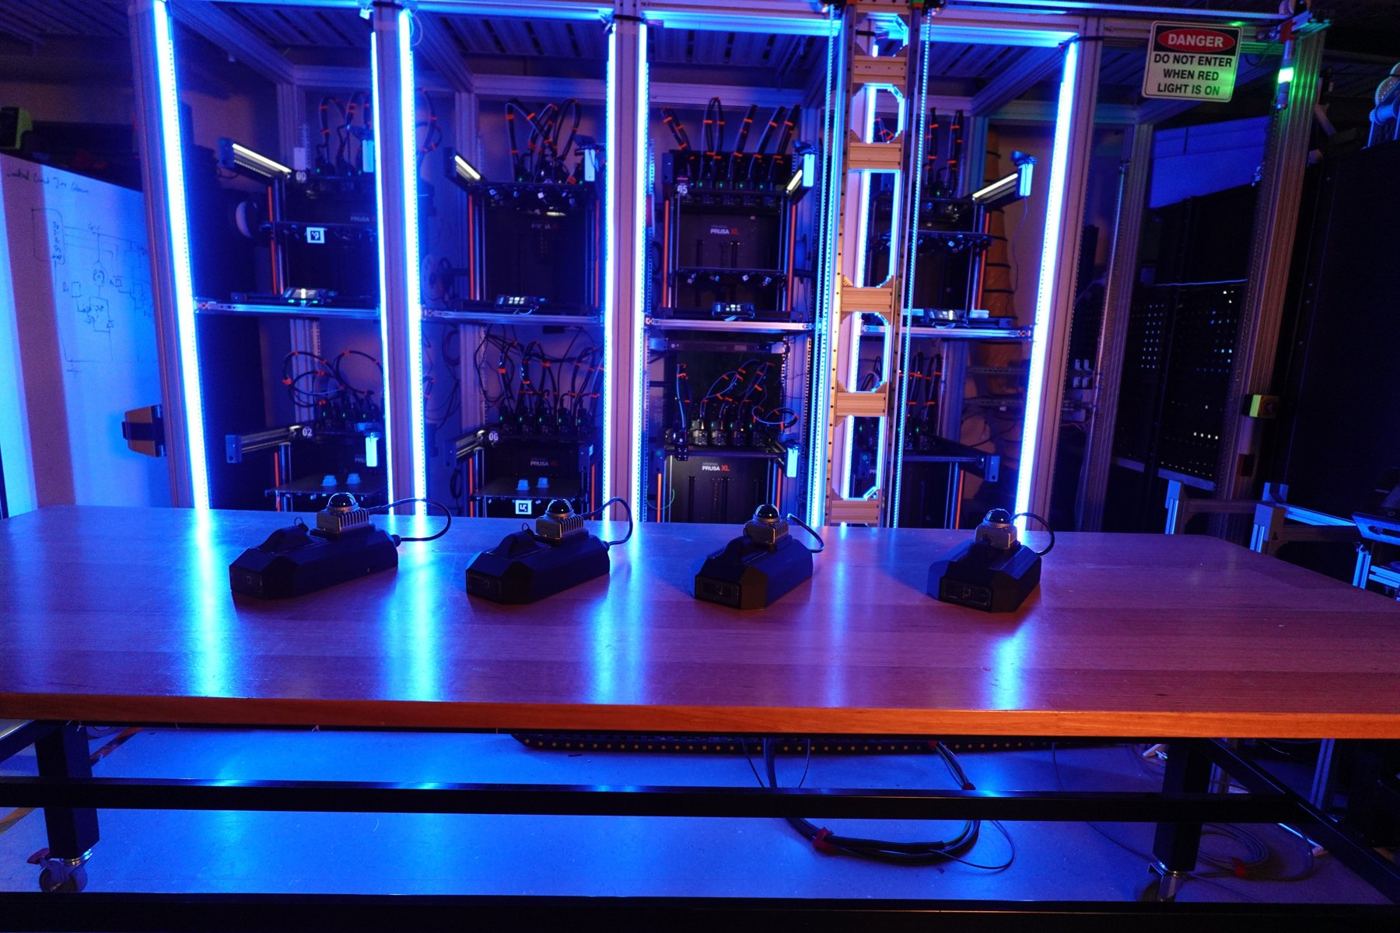
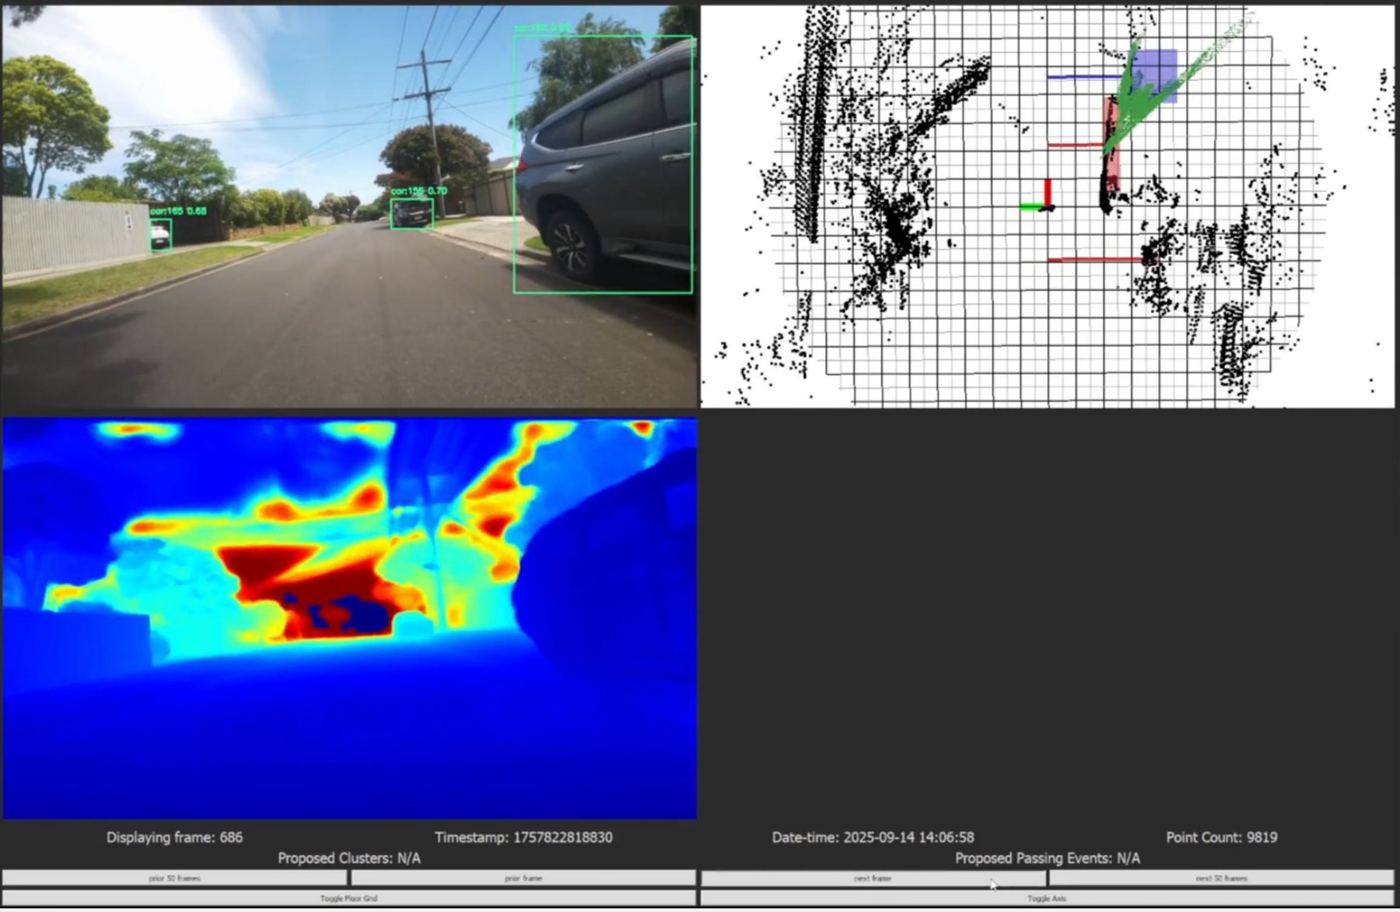
The goal of the Bike Box is to collect camera and LiDAR data to visually detect cars and measure their distance from cyclists, focusing on how far cars stay away while overtaking. The project stems from a collaboration between Monash Public Health and Preventive Medicine and Monash Robotics, developing a system for the University of British Columbia to conduct the data collection.
Monash Automation's involvement began with on-bike testing and grew into developing the box's charging system and eventually its storage, power and software systems. Every test turned up more systems that needed redesign or improvement to increase reliability.
Engineering challenges
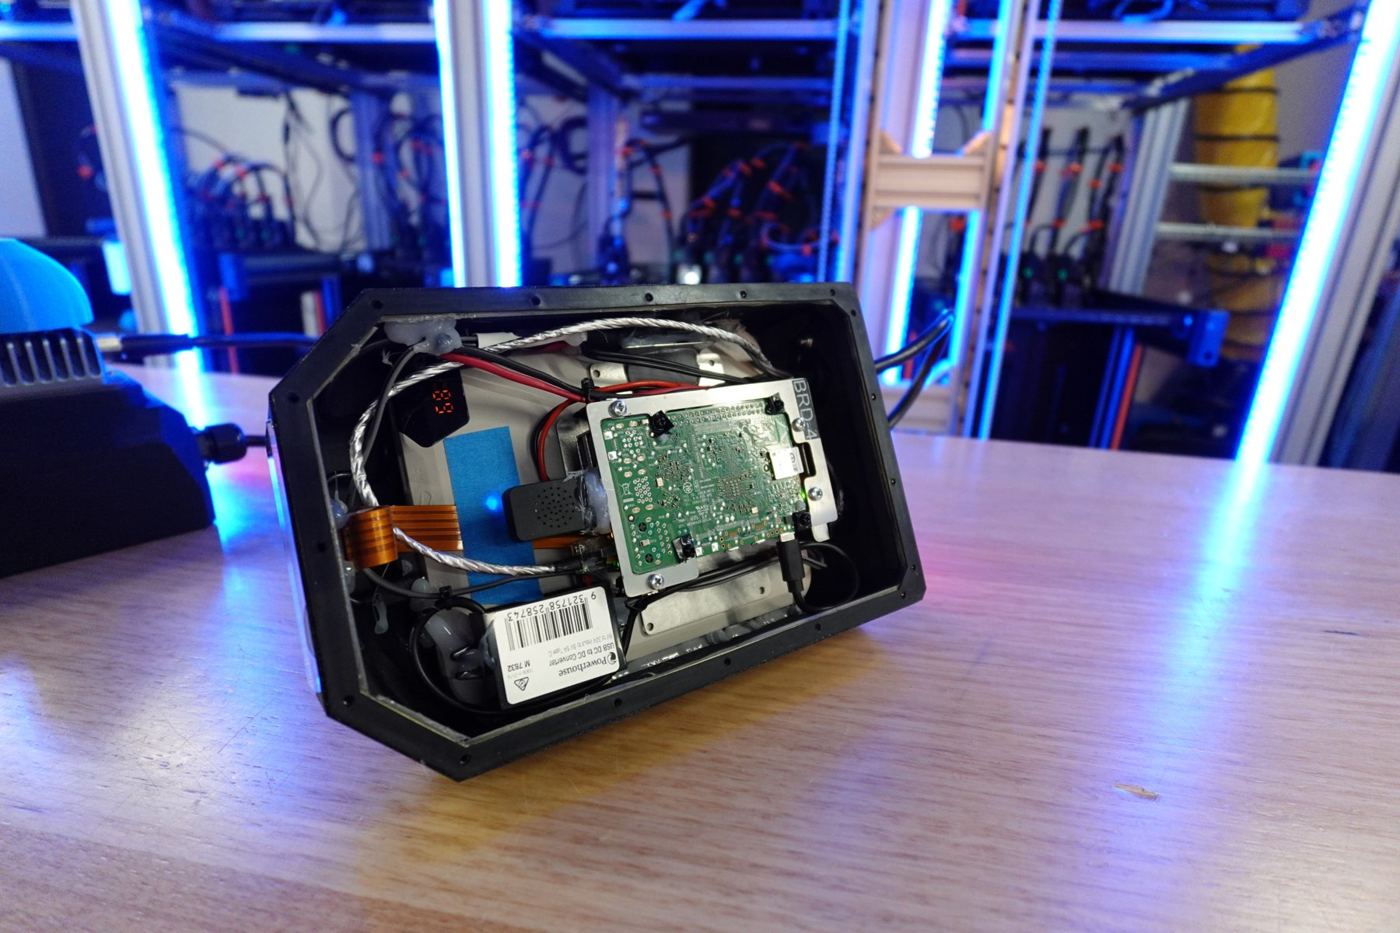
The platform is built around a Raspberry Pi combining camera and LiDAR recording with power delivery and storage that needed substantial engineering to survive sustained on-bike use. Brownouts under load meant replacing the buck converter, and both the SSDs and WiFi adapters went through several rounds of testing before reliable options were found.
Synchronising the phone and the box was another layer of complexity, as two independent devices tried frame-by-frame alignment. This was brought to within roughly half a second, measured precisely with a QR code time-testing setup that flashes timestamped codes for automatic offset detection. Ongoing work refines the LiDAR clustering pipeline to filter for vehicles rather than static objects like trees and poles, and automates data ingest and processing.