HARP
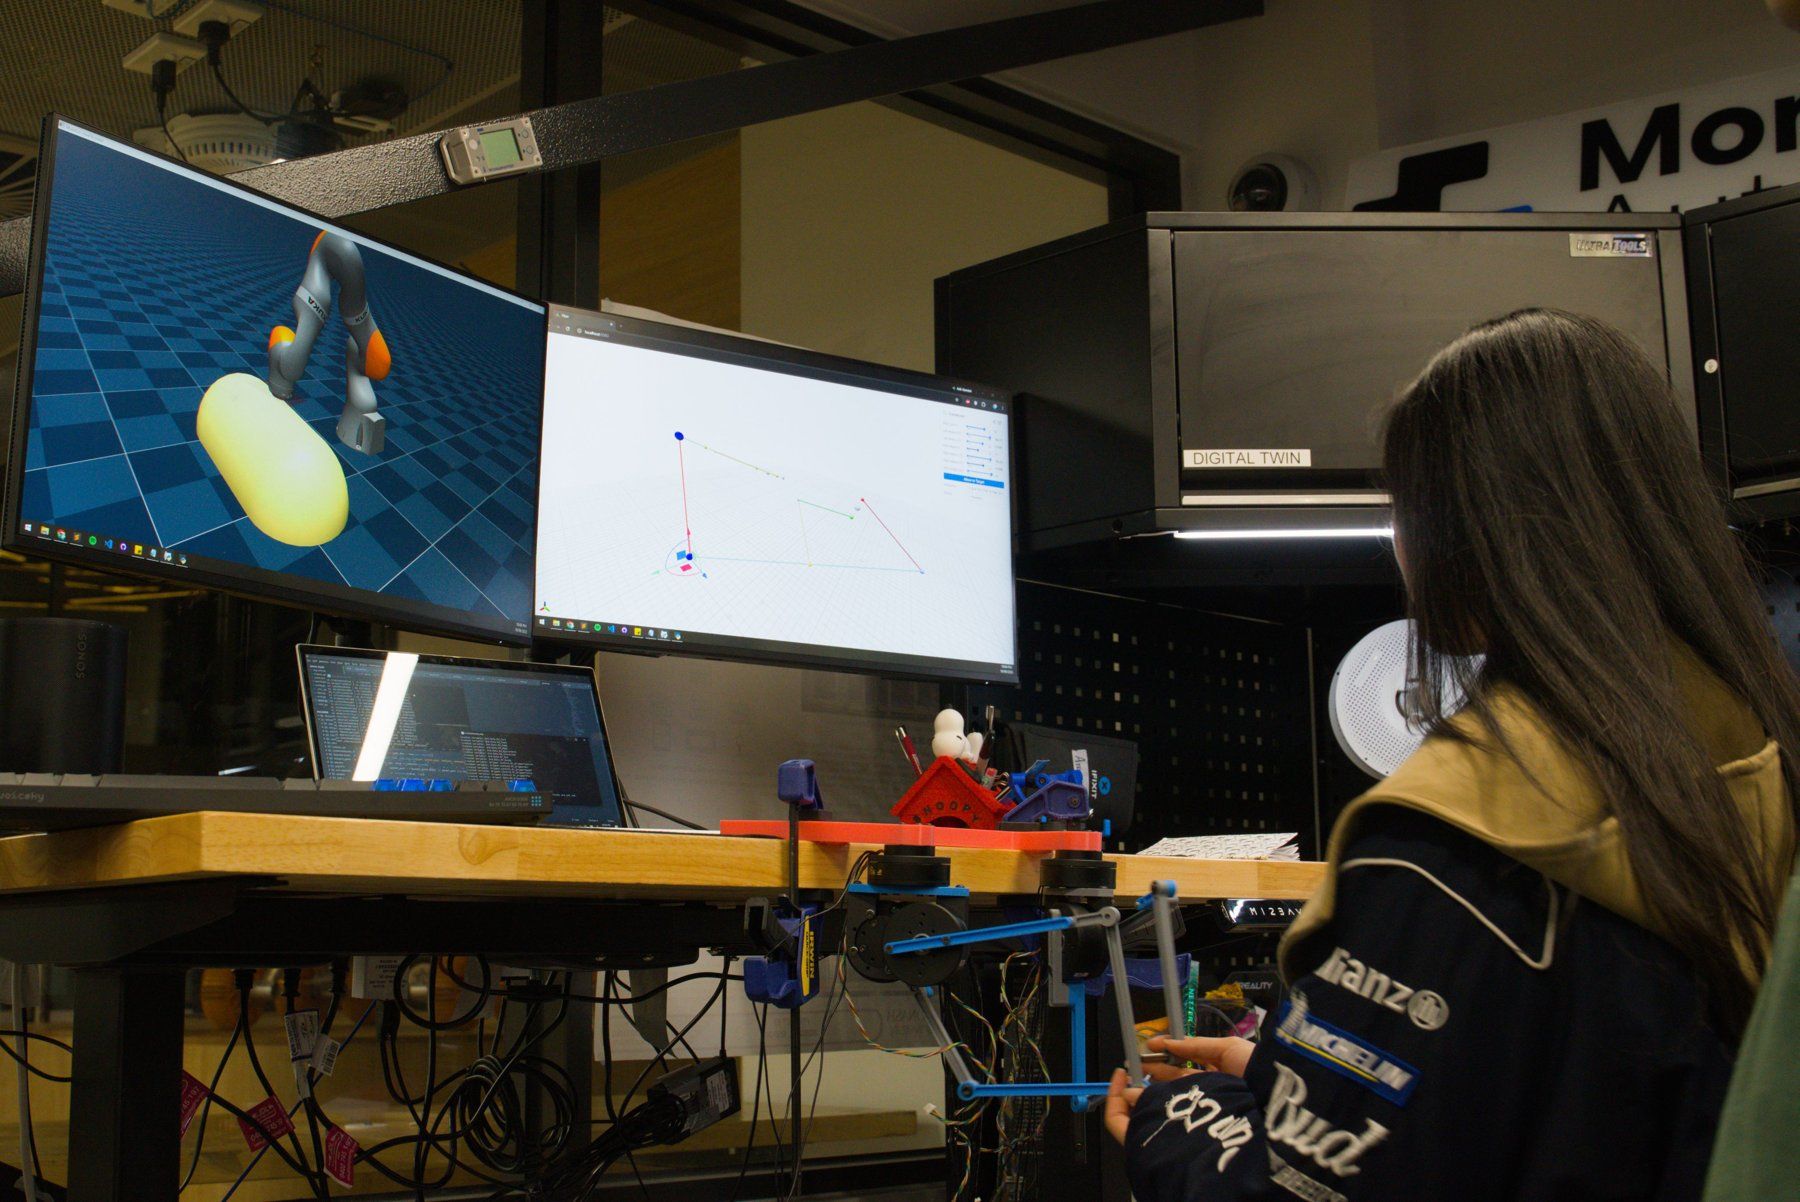
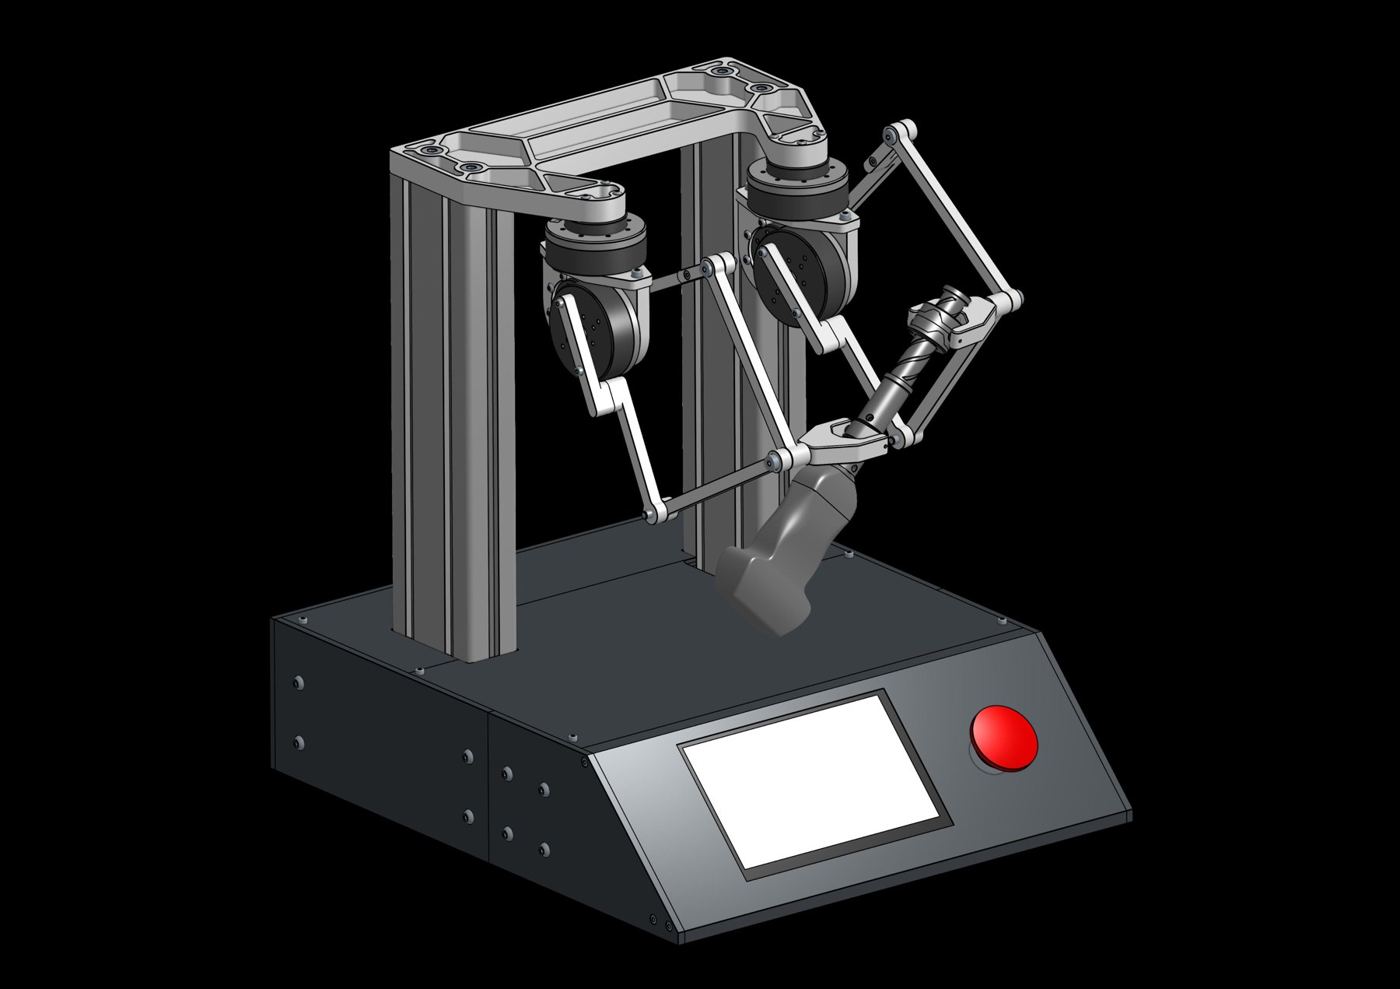
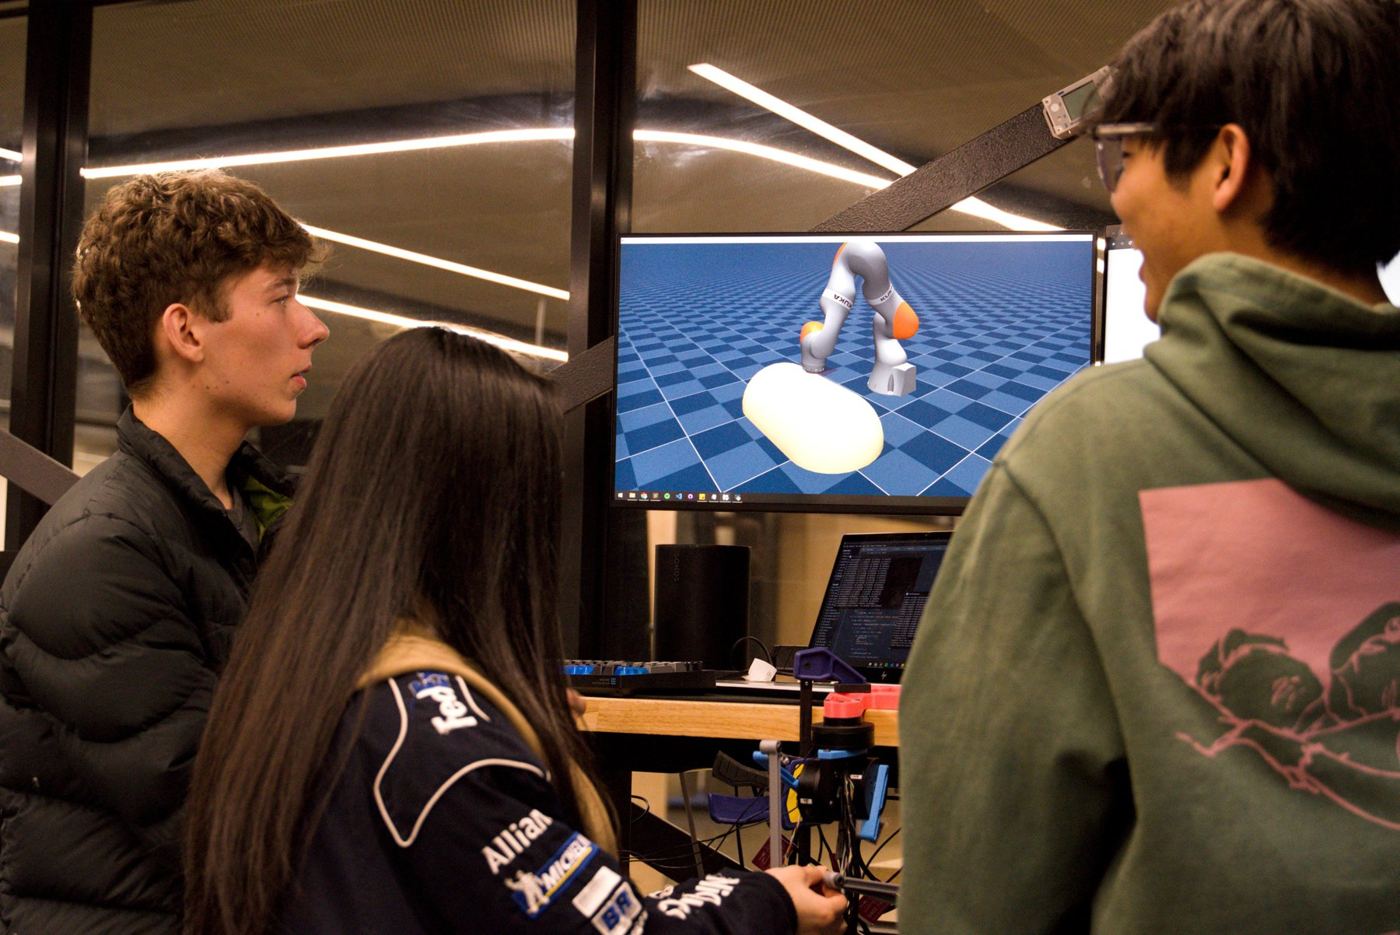
Project HARP is a 6 degree-of-freedom haptic controller system that assists in performing ultrasounds with a KUKA robotic arm.
- Program
- MedTech
- Status
- Prototyping
- Project lead
- Greta Young
- Full name
- Haptic Actuated Robotic Probe
Overview
This project set out to develop and build a true parallel 6-DOF controller with haptic feedback to manipulate a KUKA robotic arm. The immediate focus is relieving sonographers of the repetitive strain injuries caused by prolonged scanning, but the underlying technology is engineered to extend well beyond the clinic, with the potential to reshape human-robot interaction across numerous industries.
The team
Greta Young · LeadDennis YahnovGeorgia ZhouAldrich LiemAustin Huang