Initiatives / Smart Systems & Robotics
WADDl.3
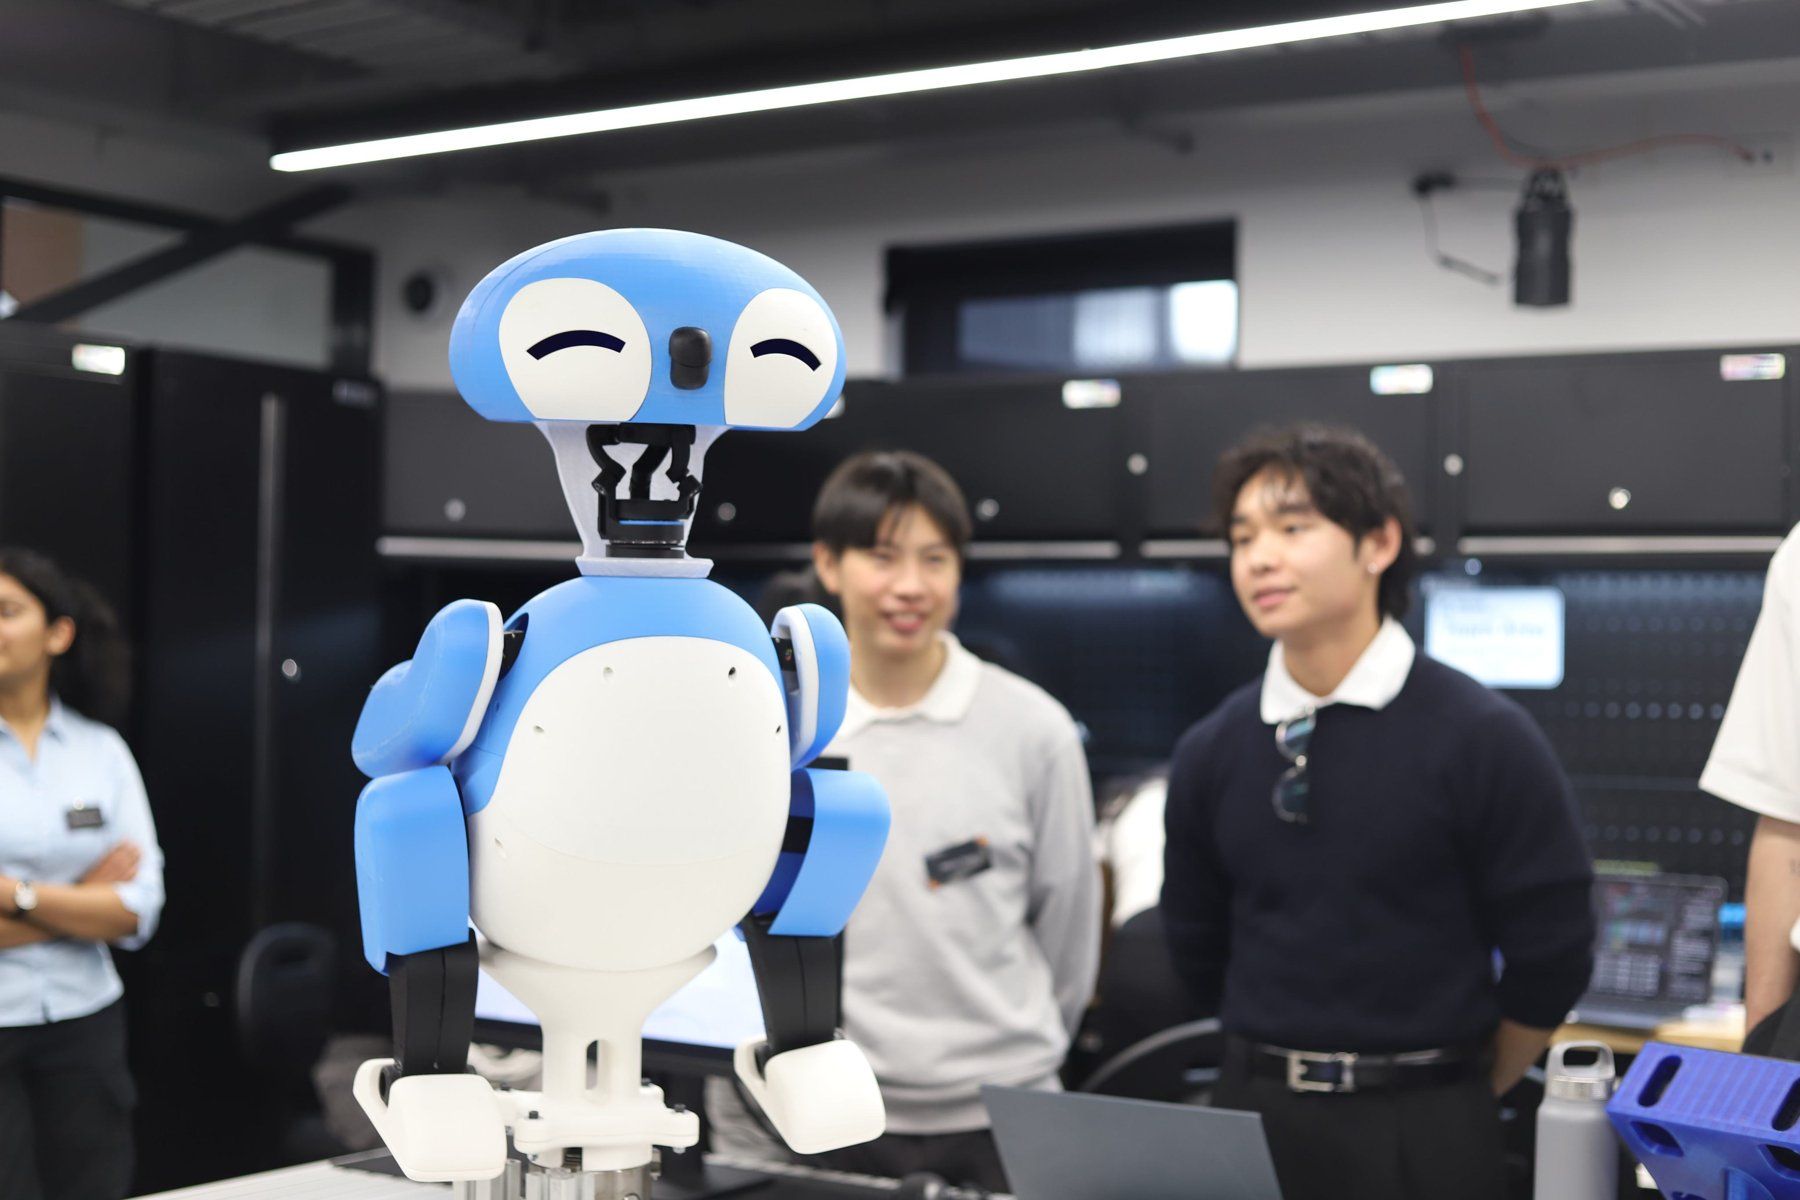
Monash Automation's bipedal robotic penguin, built to bring advanced robotics research to life. Custom mechanics, intelligent control, sensing and ROS 2, exploring how to make a robot balance, walk and move autonomously.
- Program
- Smart Systems & Robotics
- Status
- Training
- Project lead
- Aydin Chowdhury
- Stack
- Jetson, ROS 2, NVIDIA Isaac Sim
Inside-out mechanical design
WADDl.3 marks a major shift in design philosophy from the previous iteration. Last year, development worked outside-in, beginning with the desired mascot form and then fitting the mechanical and electrical systems within it. This year, the team reversed that process.
Rather than designing around the penguin shell first, the team began with the mechanisms required for bipedal motion, then developed a dynamically stable frame around them with improved centre-of-mass placement, actuator positioning and subsystem integration. The platform brings sensing, actuation and control together through a Jetson-based ROS 2 architecture.
Ground-up design, machining and fabrication
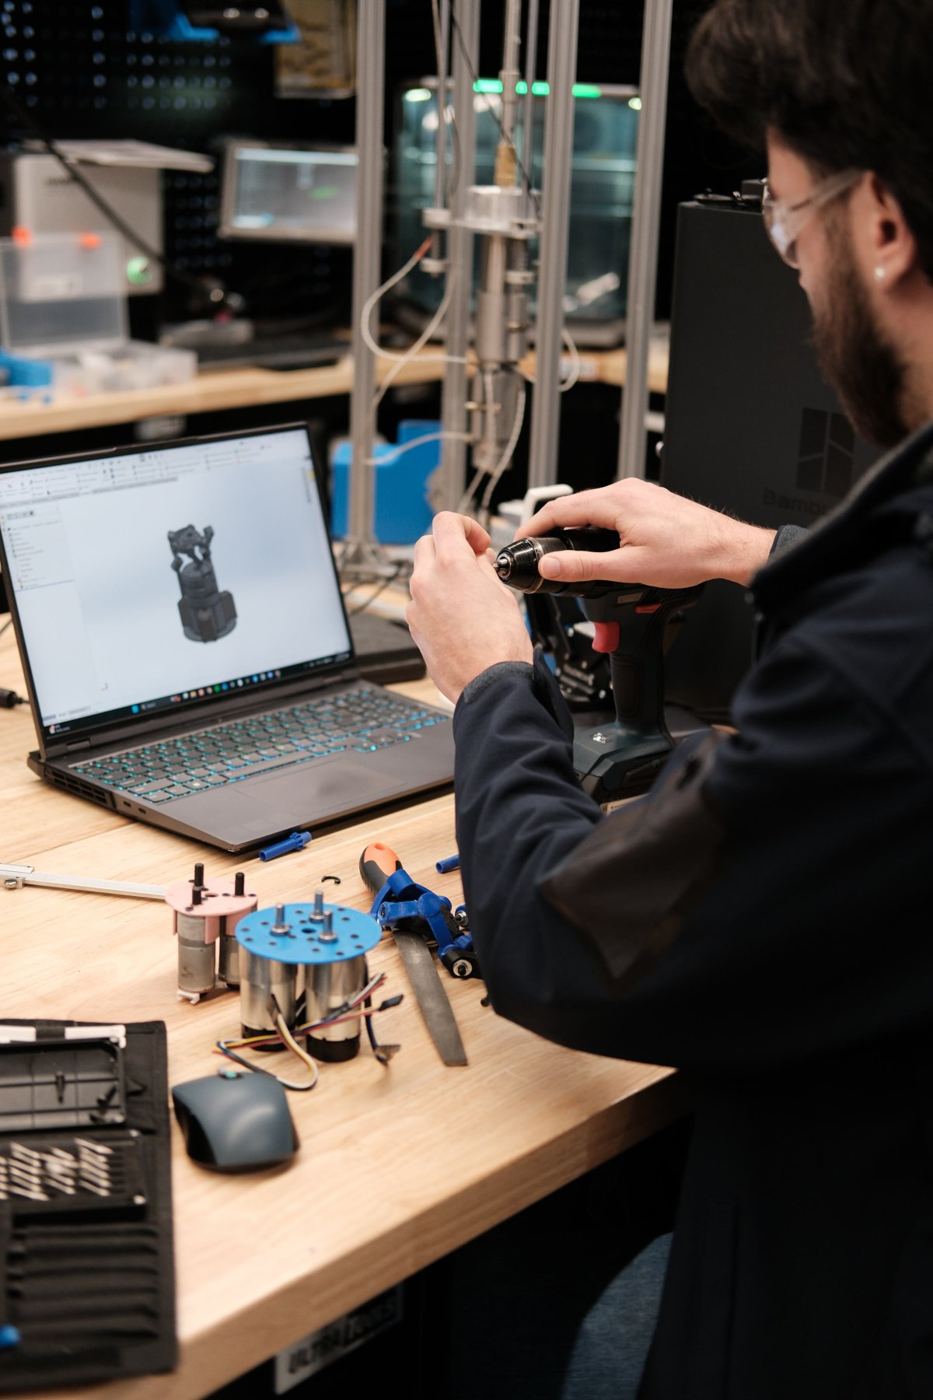
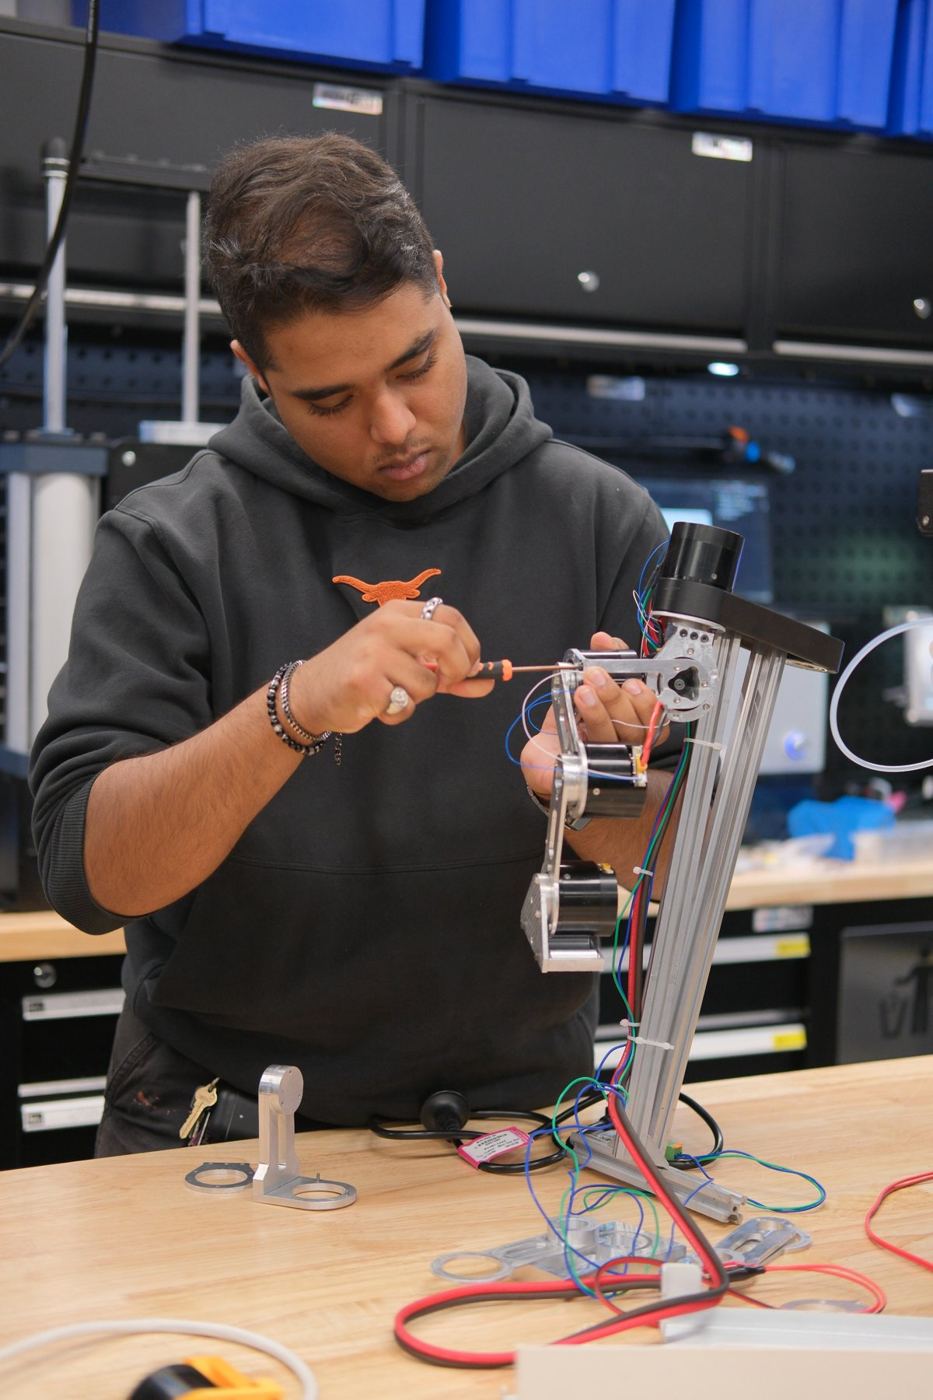
WADDl.3 has been developed from the ground up by Monash Automation. The team designs the robot's mechanical structure, joint geometry, actuator integration, bodywork and supporting hardware, rather than relying on a commercially proven platform. Custom components are developed in CAD before being machined, 3D printed and fabricated in-house.
Every mechanical decision influences the rest of the system. Joint geometry affects torque requirements, actuator selection, power consumption and control behaviour, while manufacturing tolerances and stiffness directly influence how closely the physical robot matches simulation.
Simulation, training and locomotion
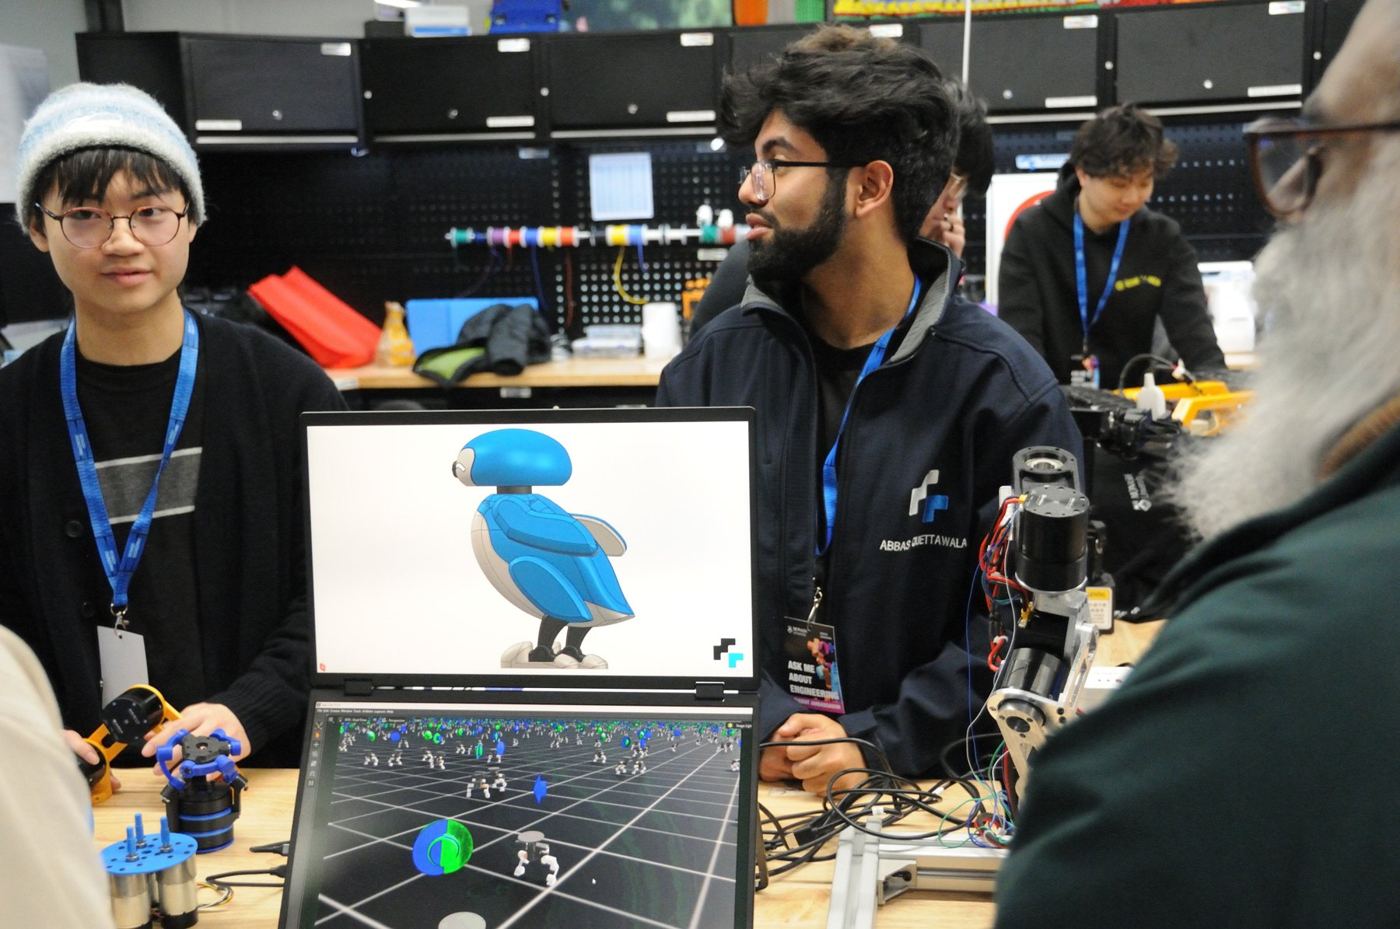
WADDl.3 is recreated as a digital model in NVIDIA Isaac Sim, so the team can develop and test locomotion strategies before deploying them onto the physical robot. The simulation supports reinforcement learning, inverse kinematics, gait planning and balance-control development in a repeatable, lower-risk environment.