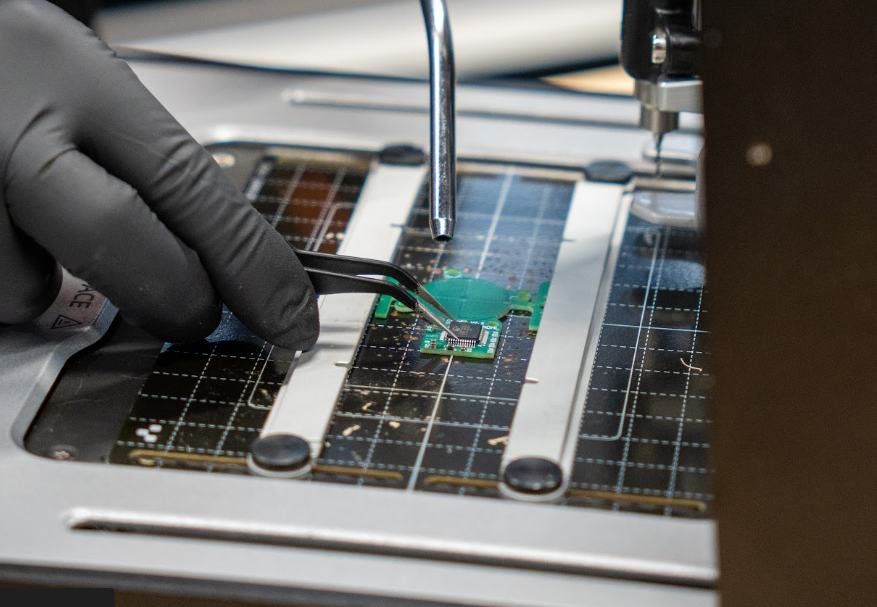
6-DOF Force Sensing Tool
A CoinFT sensor-instrumented multi-bit screwdriver that captures 6-DOF force and torque data during manual screwdriving, to train a KUKA robot arm to replicate human-like manipulation forces.
- Program
- Manufacturing
- Status
- Prototyping
- Project lead
- Aylin Cemiloglu
- Project advisor
- Dr Charles Troeung
- Project for
- Monash Robotics
Project motivation
To train a robot arm to perform manual tool tasks with the dexterity and precision of a human, we need force and torque data from those tasks as they are actually performed by hand. A handheld tool instrumented with its own F/T sensor lets us capture that data directly.
Two sensing approaches
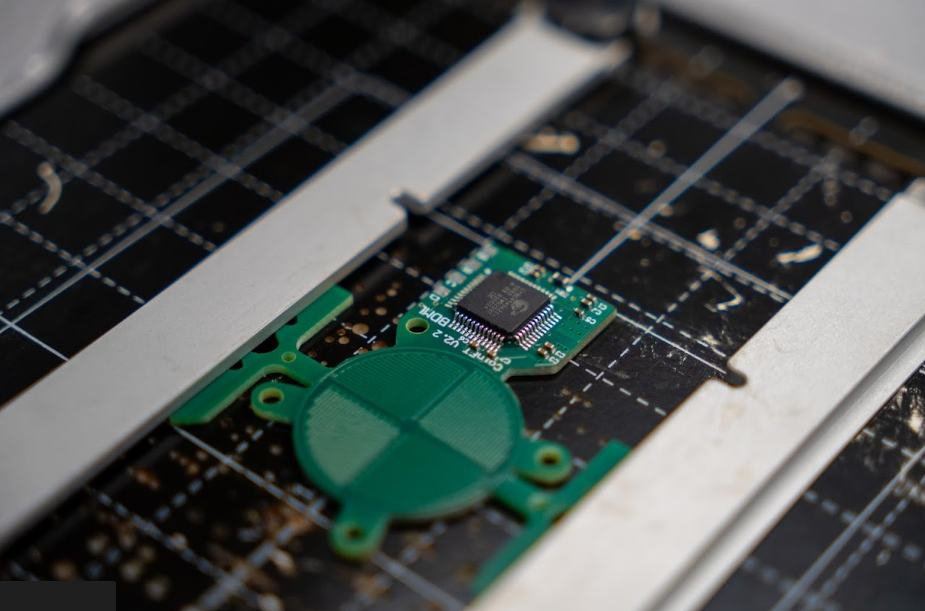
Capacitive sensor. Based on the CoinFT, an existing PCB design that measures compressive forces and torques in all six axes. Two PCBs with a silicon dielectric between them act as a capacitor; changes in capacitance are read by a PSoC chip with a capacitance-to-digital converter and sent over serial to a microcontroller and on to a computer by USB.
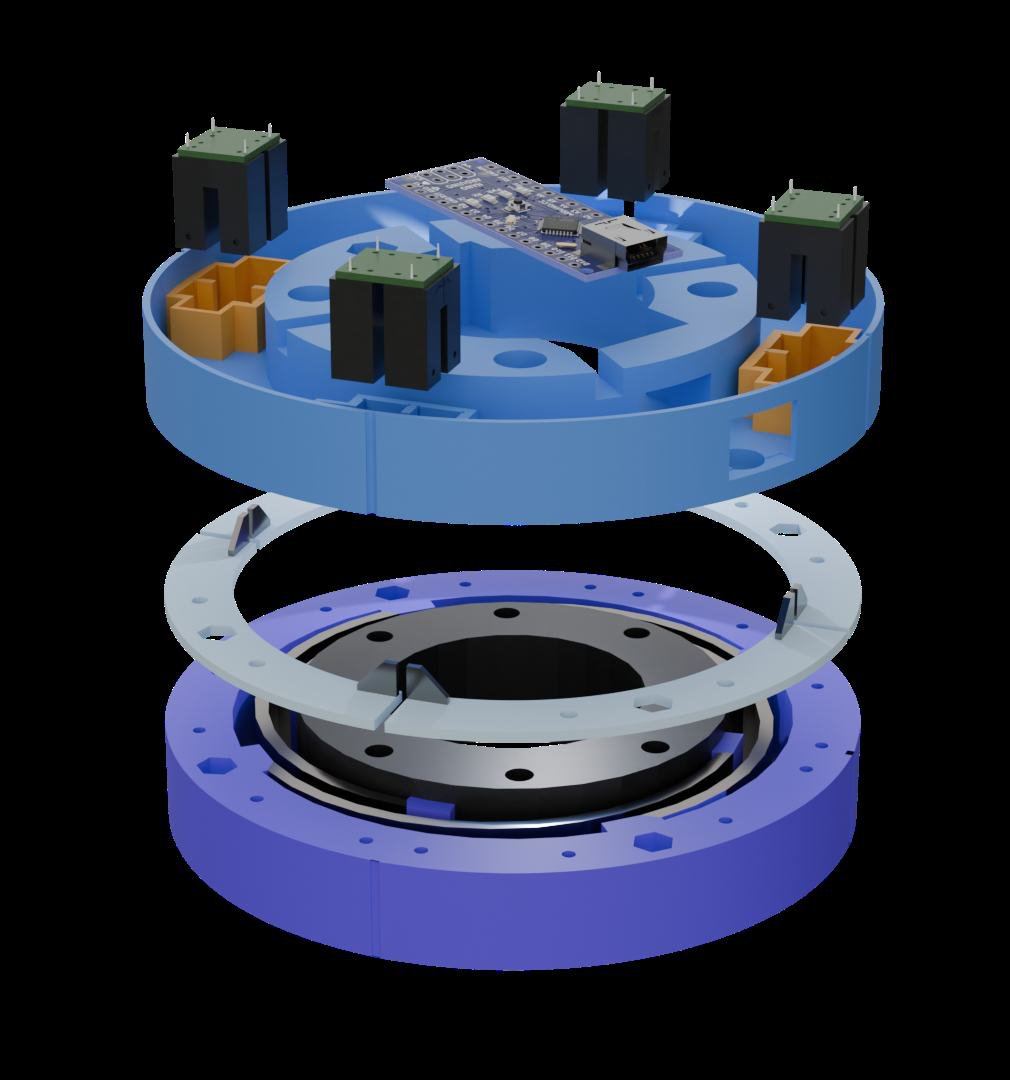
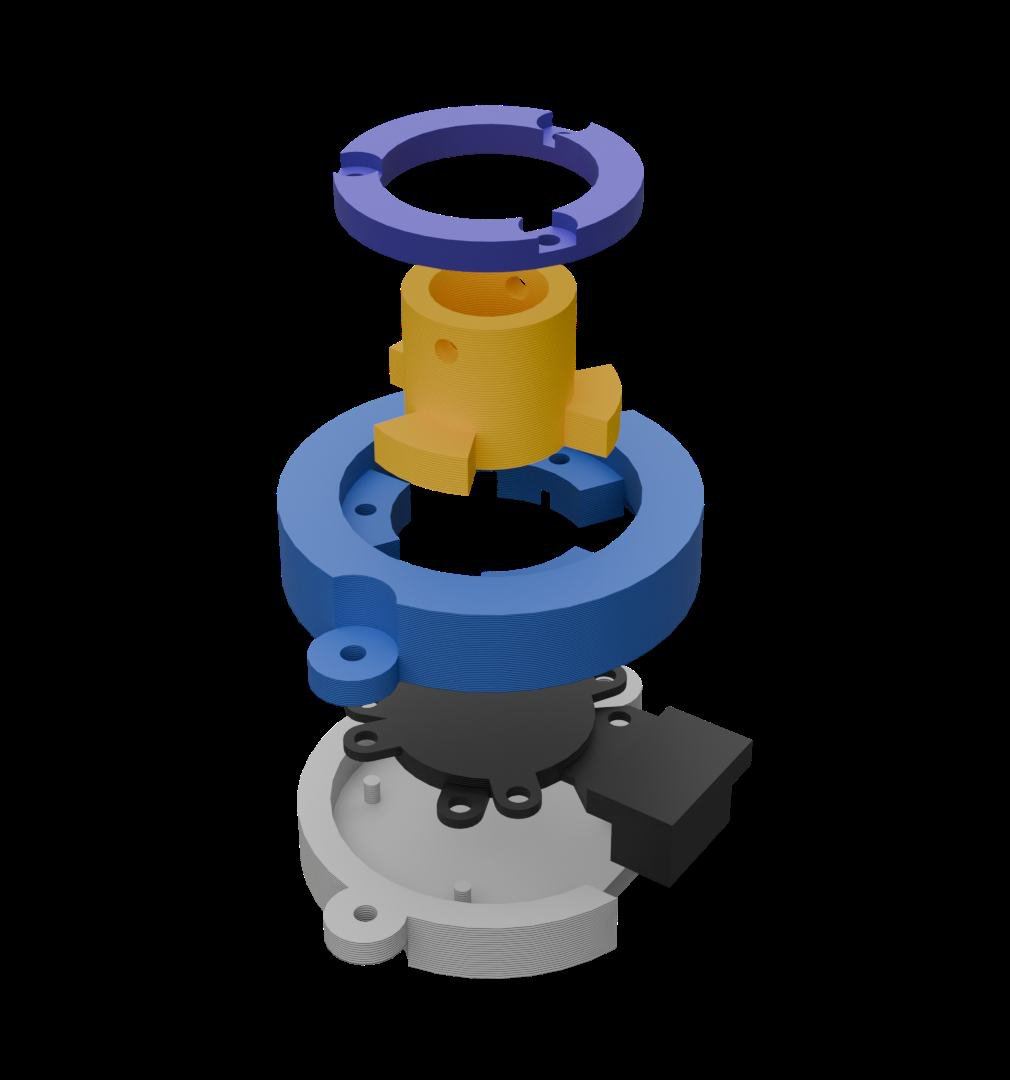
3D-printed sensor. Screwdriver motion is transferred to a 3D-printed torsion spring structure, whose fins move within photointerruptors. The resulting current changes are converted to digital data by an Arduino Nano and sent to a computer by USB.