GLaDOS
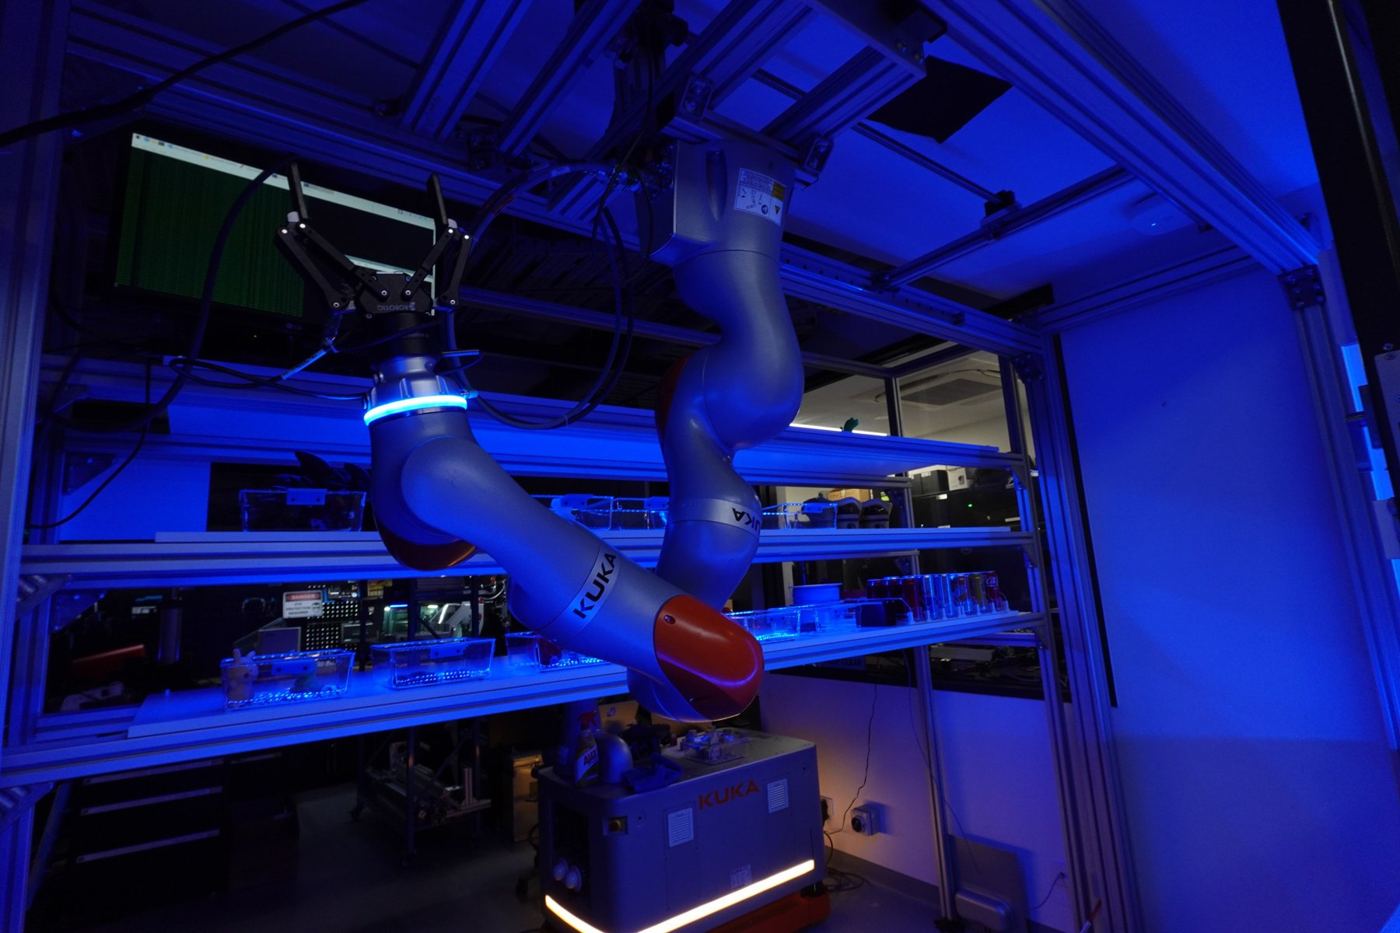
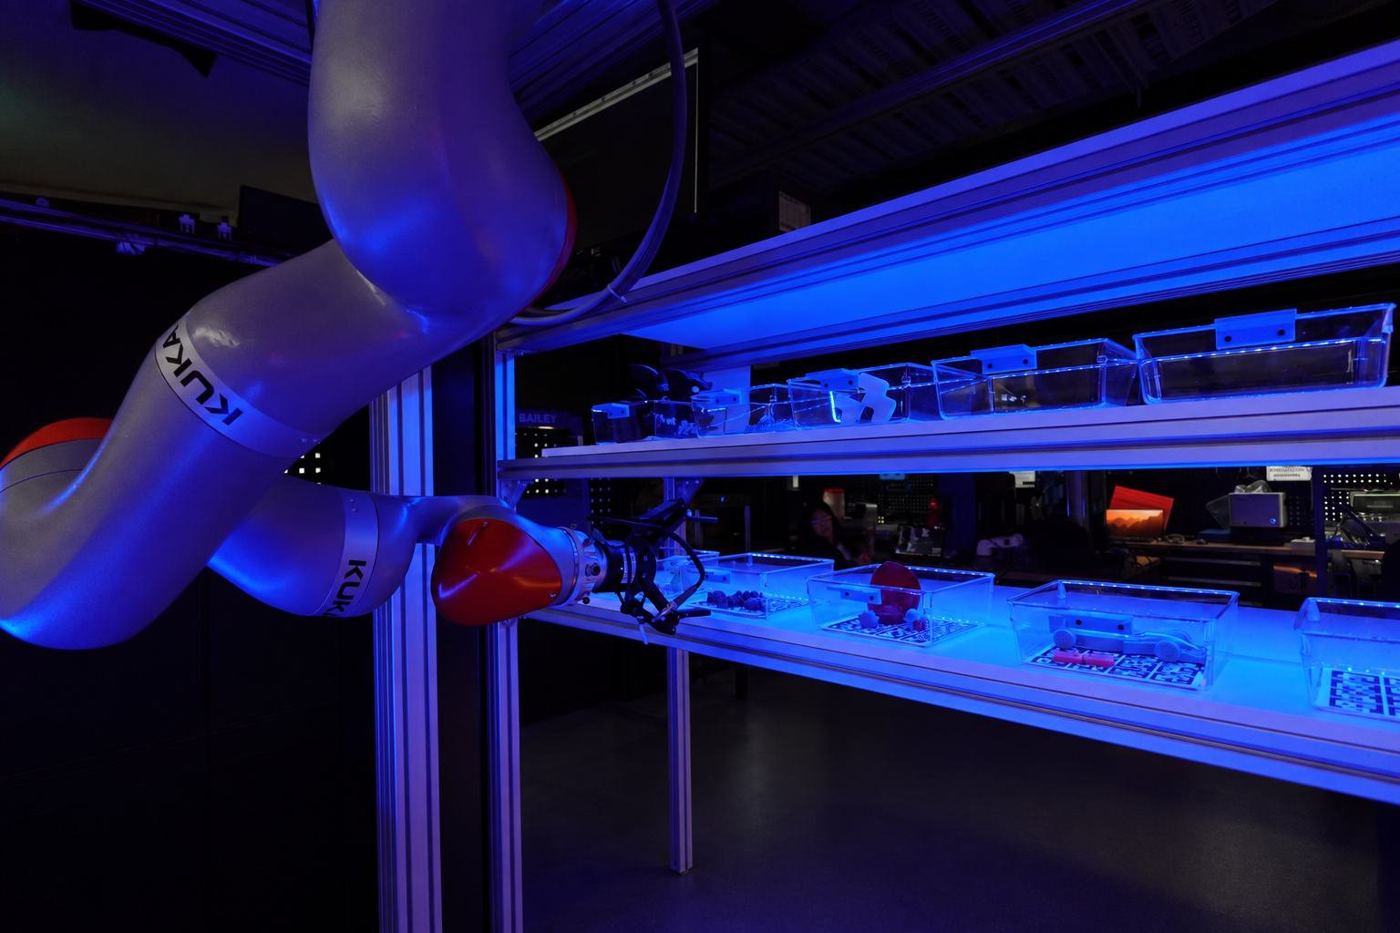
An automated 3D print collection service in the Monash Automation Lab, centred on a Human Robot Interaction window.
- Program
- Manufacturing
- Status
- Deployed
- Project leads
- Rain Lai, Henry Tang
- Hardware
- KUKA LBR iiwa, Intel RealSense D405
Project motivation
In makerspaces and robotics labs, retrieving and storing 3D printed parts is still done by hand. It is repetitive, takes people away from more useful work, and doesn't scale as print volume goes up.
GLaDOS gives a KUKA LBR iiwa arm the perception and manipulation skills to find, grasp and store finished prints on its own, using an eye-in-hand depth camera, while also handling user-facing features like drawing and window access. It brings together vision-guided grasping, real-time control and human-robot interaction in one working system: the kind of end-to-end pipeline mechatronics engineers are expected to build in industry.
Vision system
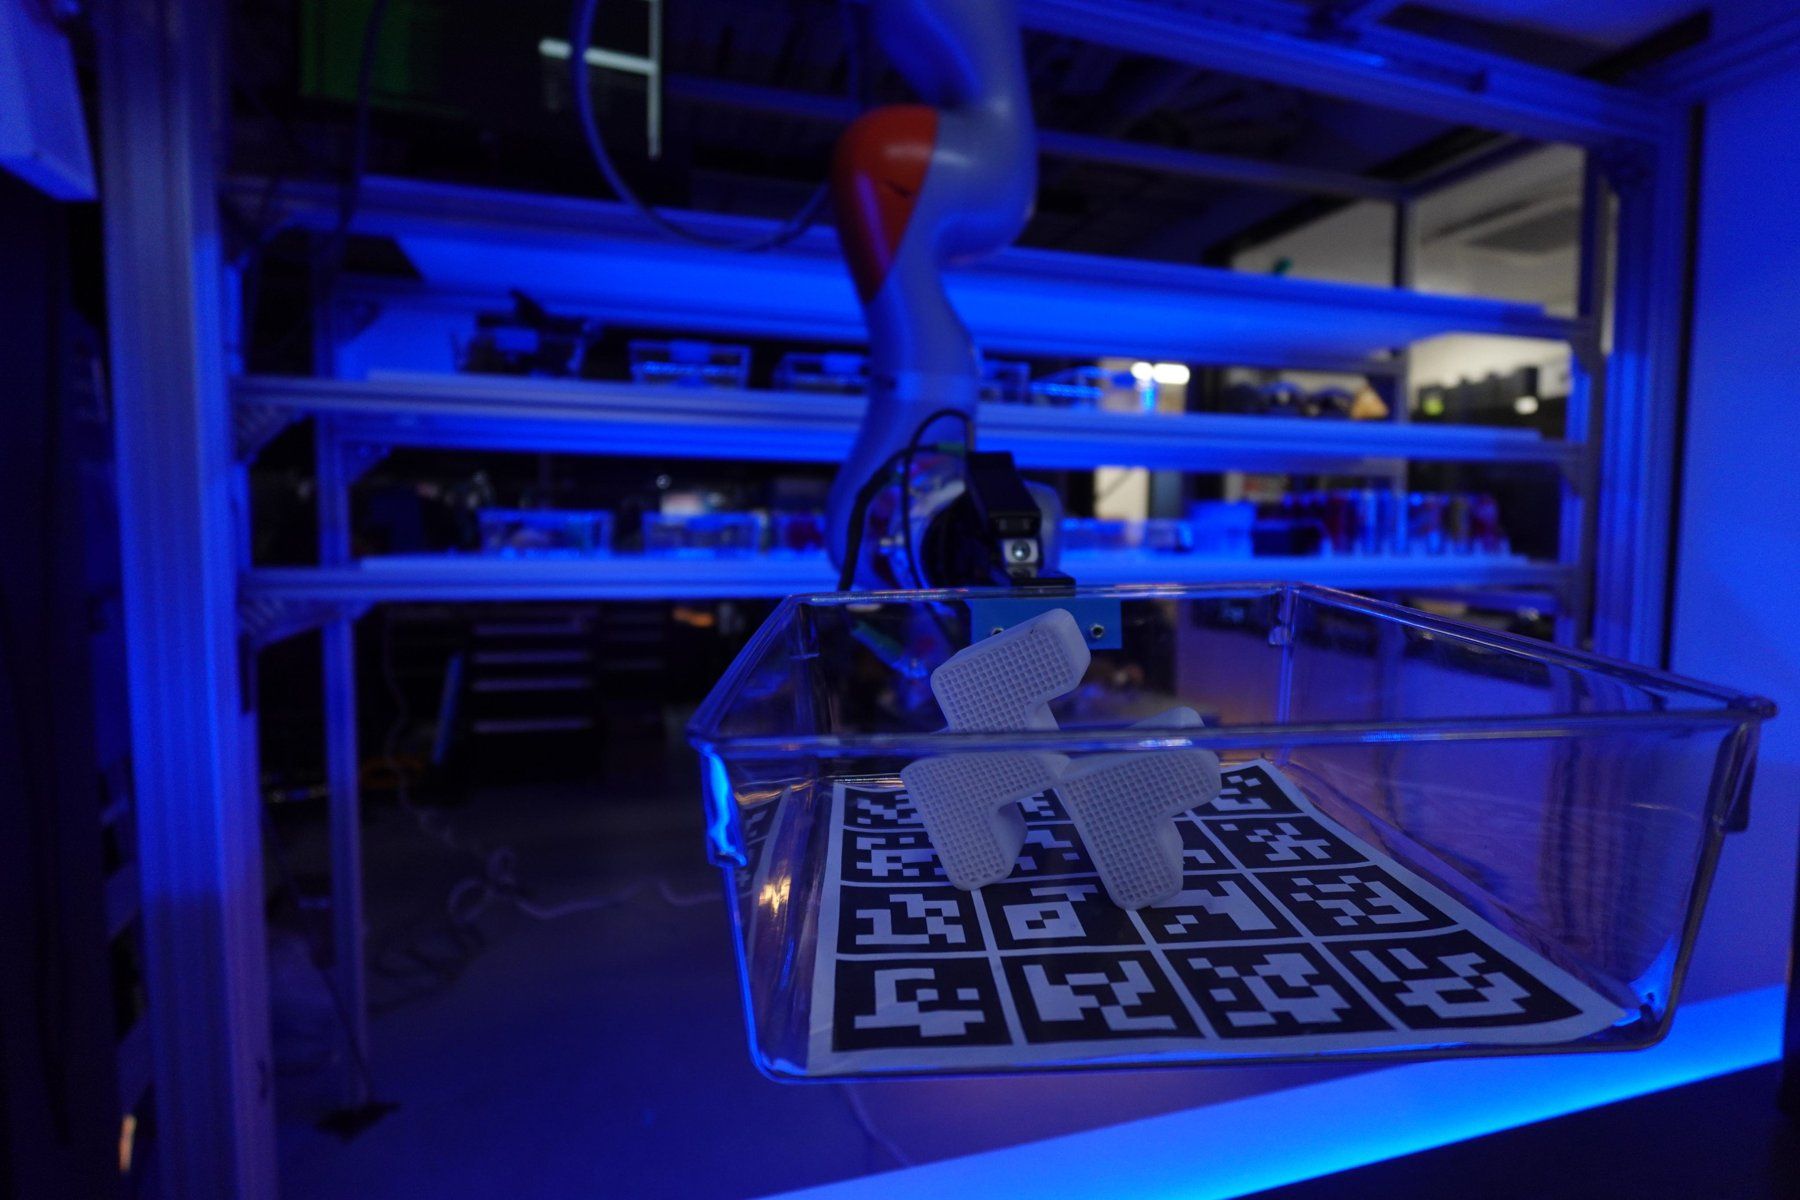
To increase safety and flexibility, a vision system automates picking up and handing out containers. An Intel RealSense D405 on the arm's end effector tracks both the containers and the items inside them. It detects where containers are, for accurate pickup and flexible placement within the storage system, and detects whether items are present so a container is never retracted while a customer is collecting their prints.
Drawing function
To build trust and interaction, the system can draw. It writes motivational sayings, draws fun characters and puts up reminders for passersby, combining image processing in Python, path creation for the KUKA arm and force sensing to bring a bit of joy to the lab.